Ambient Data Collection 2.0
Building the Foundation for Physical AI Through the Information Density Law
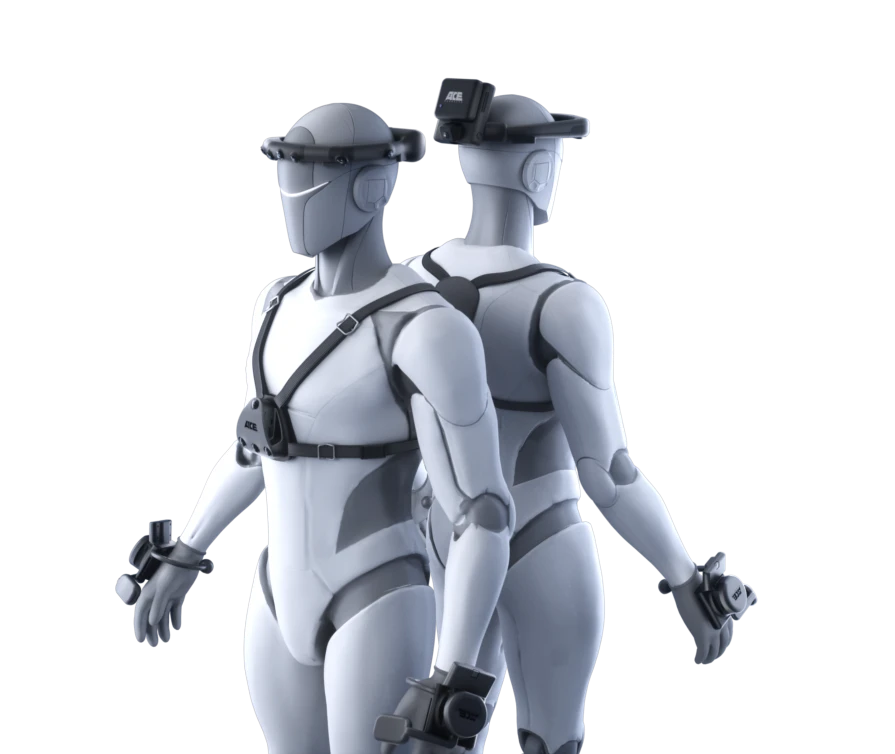
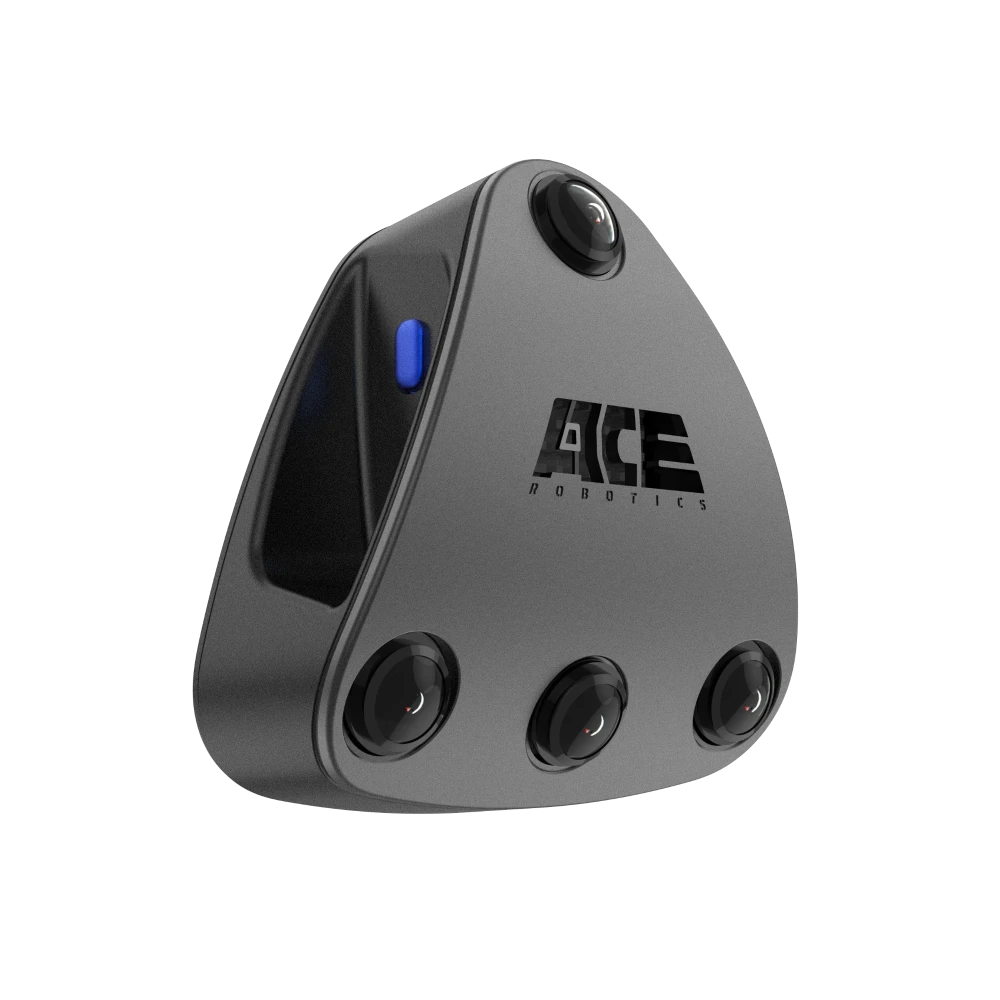
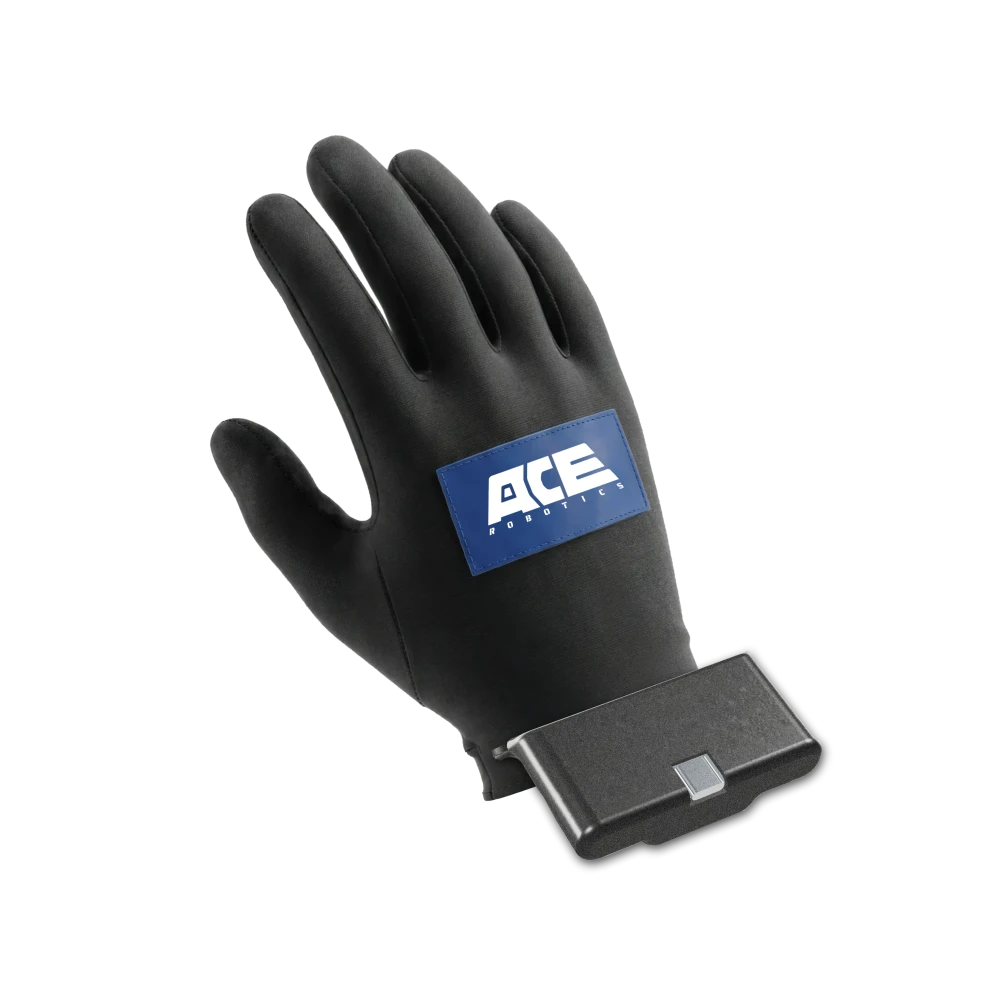
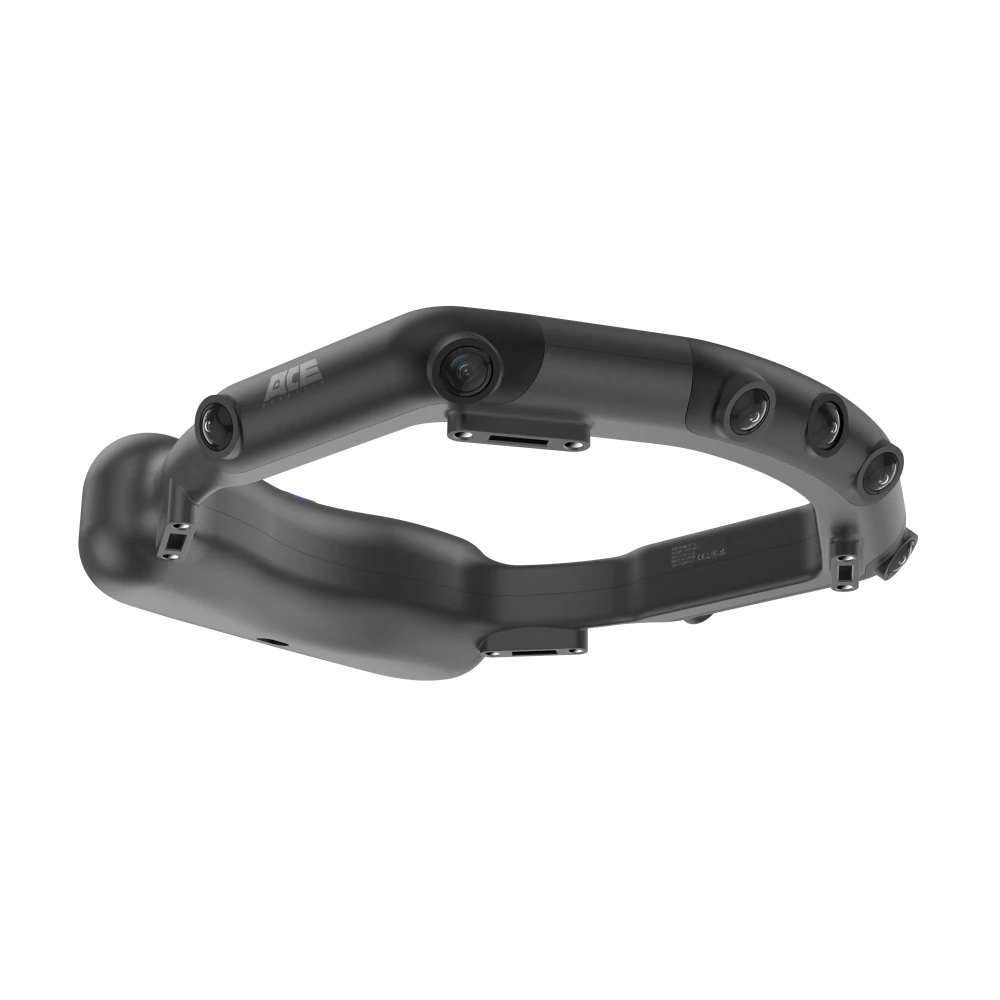
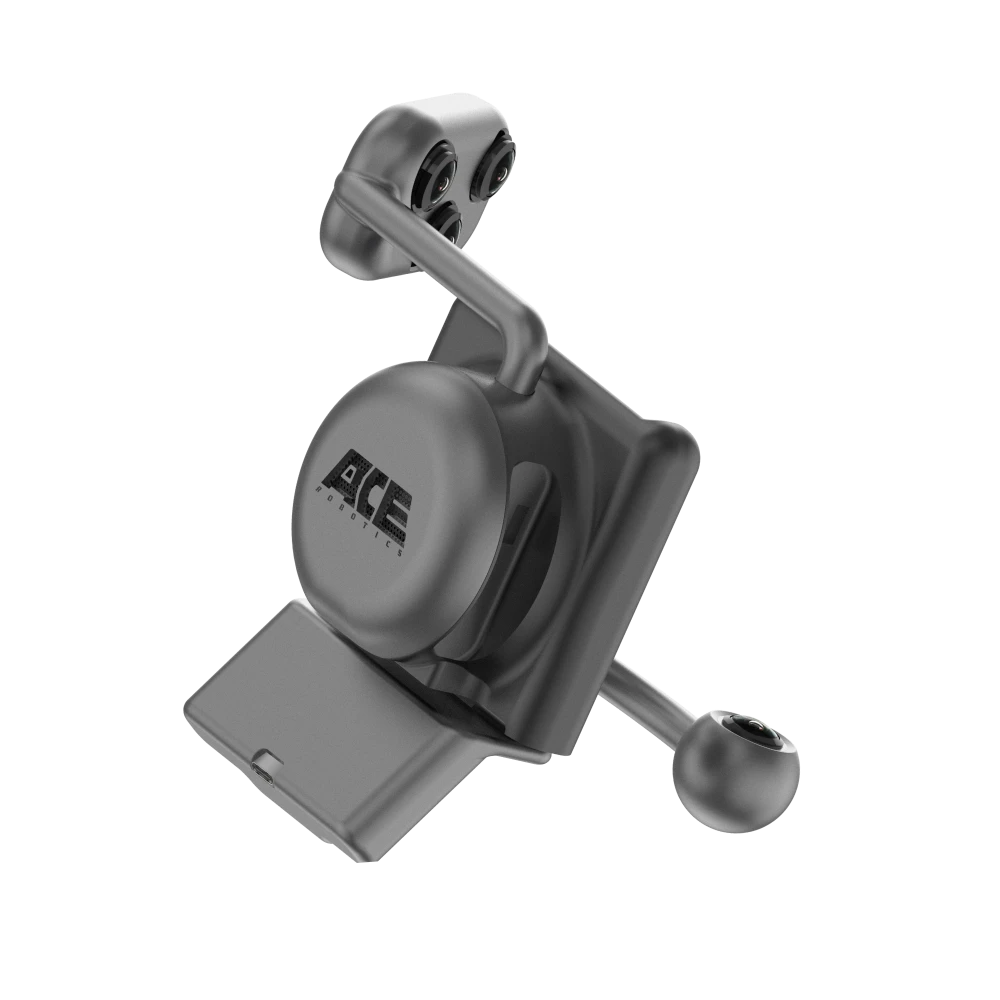

Integrated head, hand, and chest sensing captures fine-grained human–object interactions and full-body joint movements
3D force and tactile sensing with 0.01 N sensitivity and joint-angle error below 2°

Modular, lightweight, wireless design with magnetic battery swapping
Flexible configurations for diverse work scenarios

20+ heterogeneous sensors
Time synchronization error < 1 ms

A unified representation of actions in egocentric space enables movements from different people and robot models to "speak the same language"

Maps robot morphologies using URDF (Unified Robot Description Format), enabling models to identify "who is performing the action."

Temporal alignment and dynamic chunking keep data captured at different rates in sync.
A reliability-adaptive objective function allows noisy data to be weighted according to task requirements.
A unified representation of actions in egocentric space enables movements from different people and robot models to "speak the same language"
Maps robot morphologies using URDF (Unified Robot Description Format), enabling models to identify "who is performing the action."
Temporal alignment and dynamic chunking keep data captured at different rates in sync.
A reliability-adaptive objective function allows noisy data to be weighted according to task requirements.
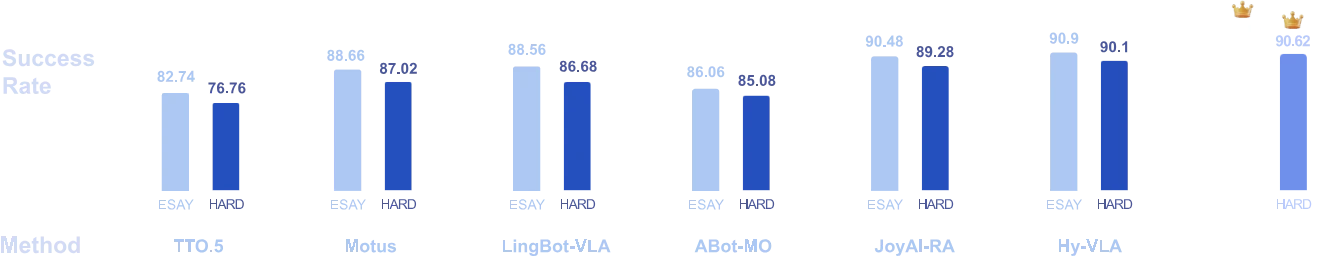
Data Engine for Physical AI
Frames
Episodes
Tasks
One Takes
Viewpoints
Modalities
Evolving Intelligence
Empowering Every Robot With A Super-Brain

Evolving Intelligence
Empowering Every Robot With A Super-Brain